1965
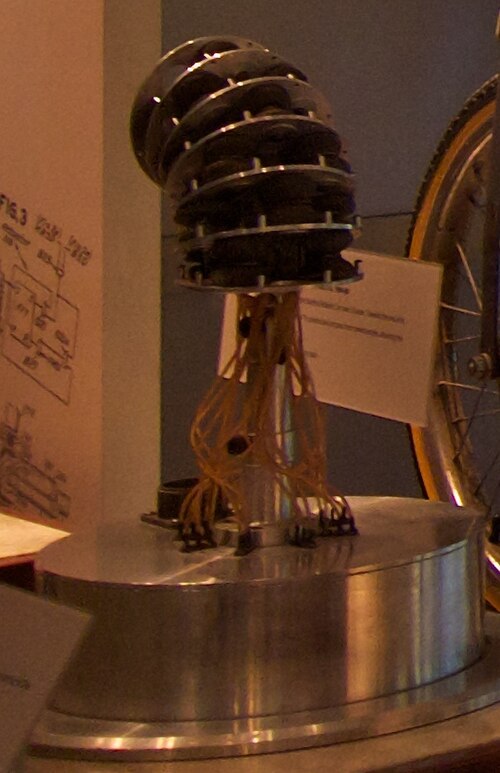
The pneumatic Orm arm
United States · Robotics
In 1965 at Stanford, Victor Scheinman and Larry Leifer built the air-powered Orm arm (Norwegian for snake): it moved by inflating 28 bladders between seven metal discs. It is one of the first attempts at an arm controlled directly by a computer, but it was abandoned because its movements were imprecise. [1][2][3]
Sources